- Role
- Set up the whole code base for Ashwin's team to build on.
- Built with
- Java
- Pedro Pathing
- FTC SDK
- Started
- Oct 2026
- Finished
- Oct 2026
Story
I gave Ashwin’s team the same structure our own robot code uses, already set up with Pedro Pathing and their hardware, so they could start on their robot’s code straight away.
How it works
- Pedro Pathing with every tuner (mecanum, each localizer, Foresight) in
pedro/. - Utilities: a command-style OpMode base, cached motors, gamepad helpers, and Kalman and low-pass filters.
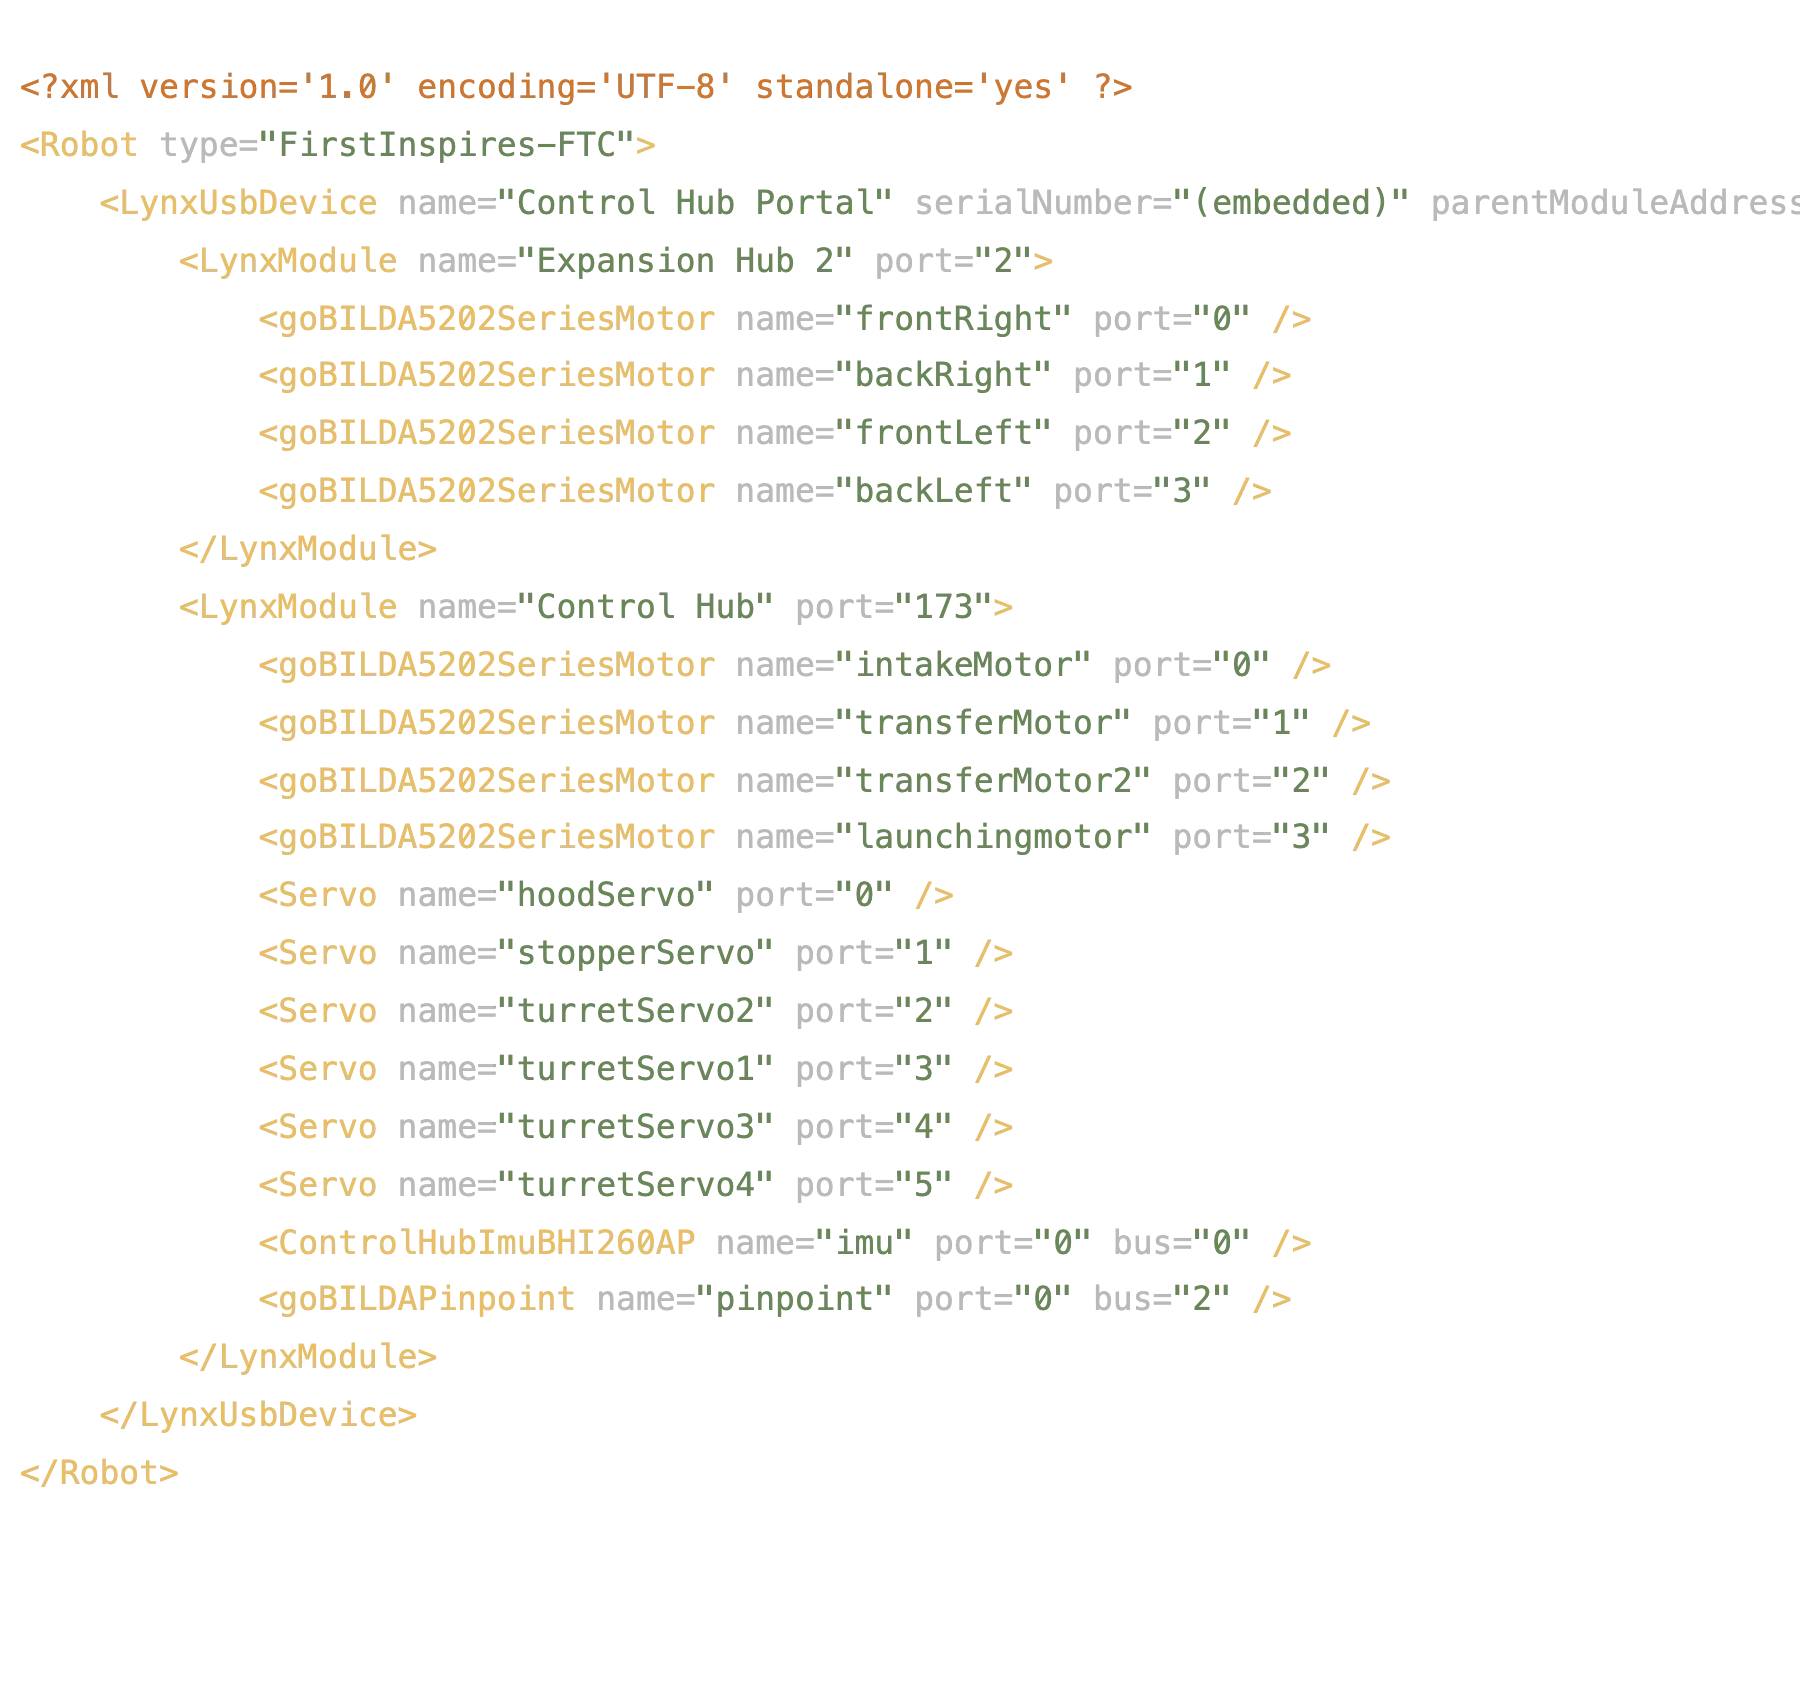
- Hardware config: their robot’s motors, servos, IMU and Pinpoint, saved from the robot so the names in code match it.