Commits named by meet day
Every commit in the BIOBUZZ repo now starts with the meet day, and badly named commits get fixed on their way in.
Number 16
ElectroLights' robot code for the 2026–27 FTC season, BIOBUZZ, with a turret that aims from a simulated shot map.
BIOBUZZ is the 2026–27 FTC game. The robot launches balls at four targets on the HIVEs, and whether a shot scores depends on where the robot is standing and which way the other HIVE is tilted.
We write the code together and commit after every meet day (D13, D14…), so the history reads like a build diary. We’re ten days and over ninety commits in, and auto logic is in testing.
The robot’s code is built on Pedro Pathing for driving and Ivy for commands, with subsystems for the intake, turret, hood, shooter, latch and flower.
Aiming comes from a lookup table, not guesswork:
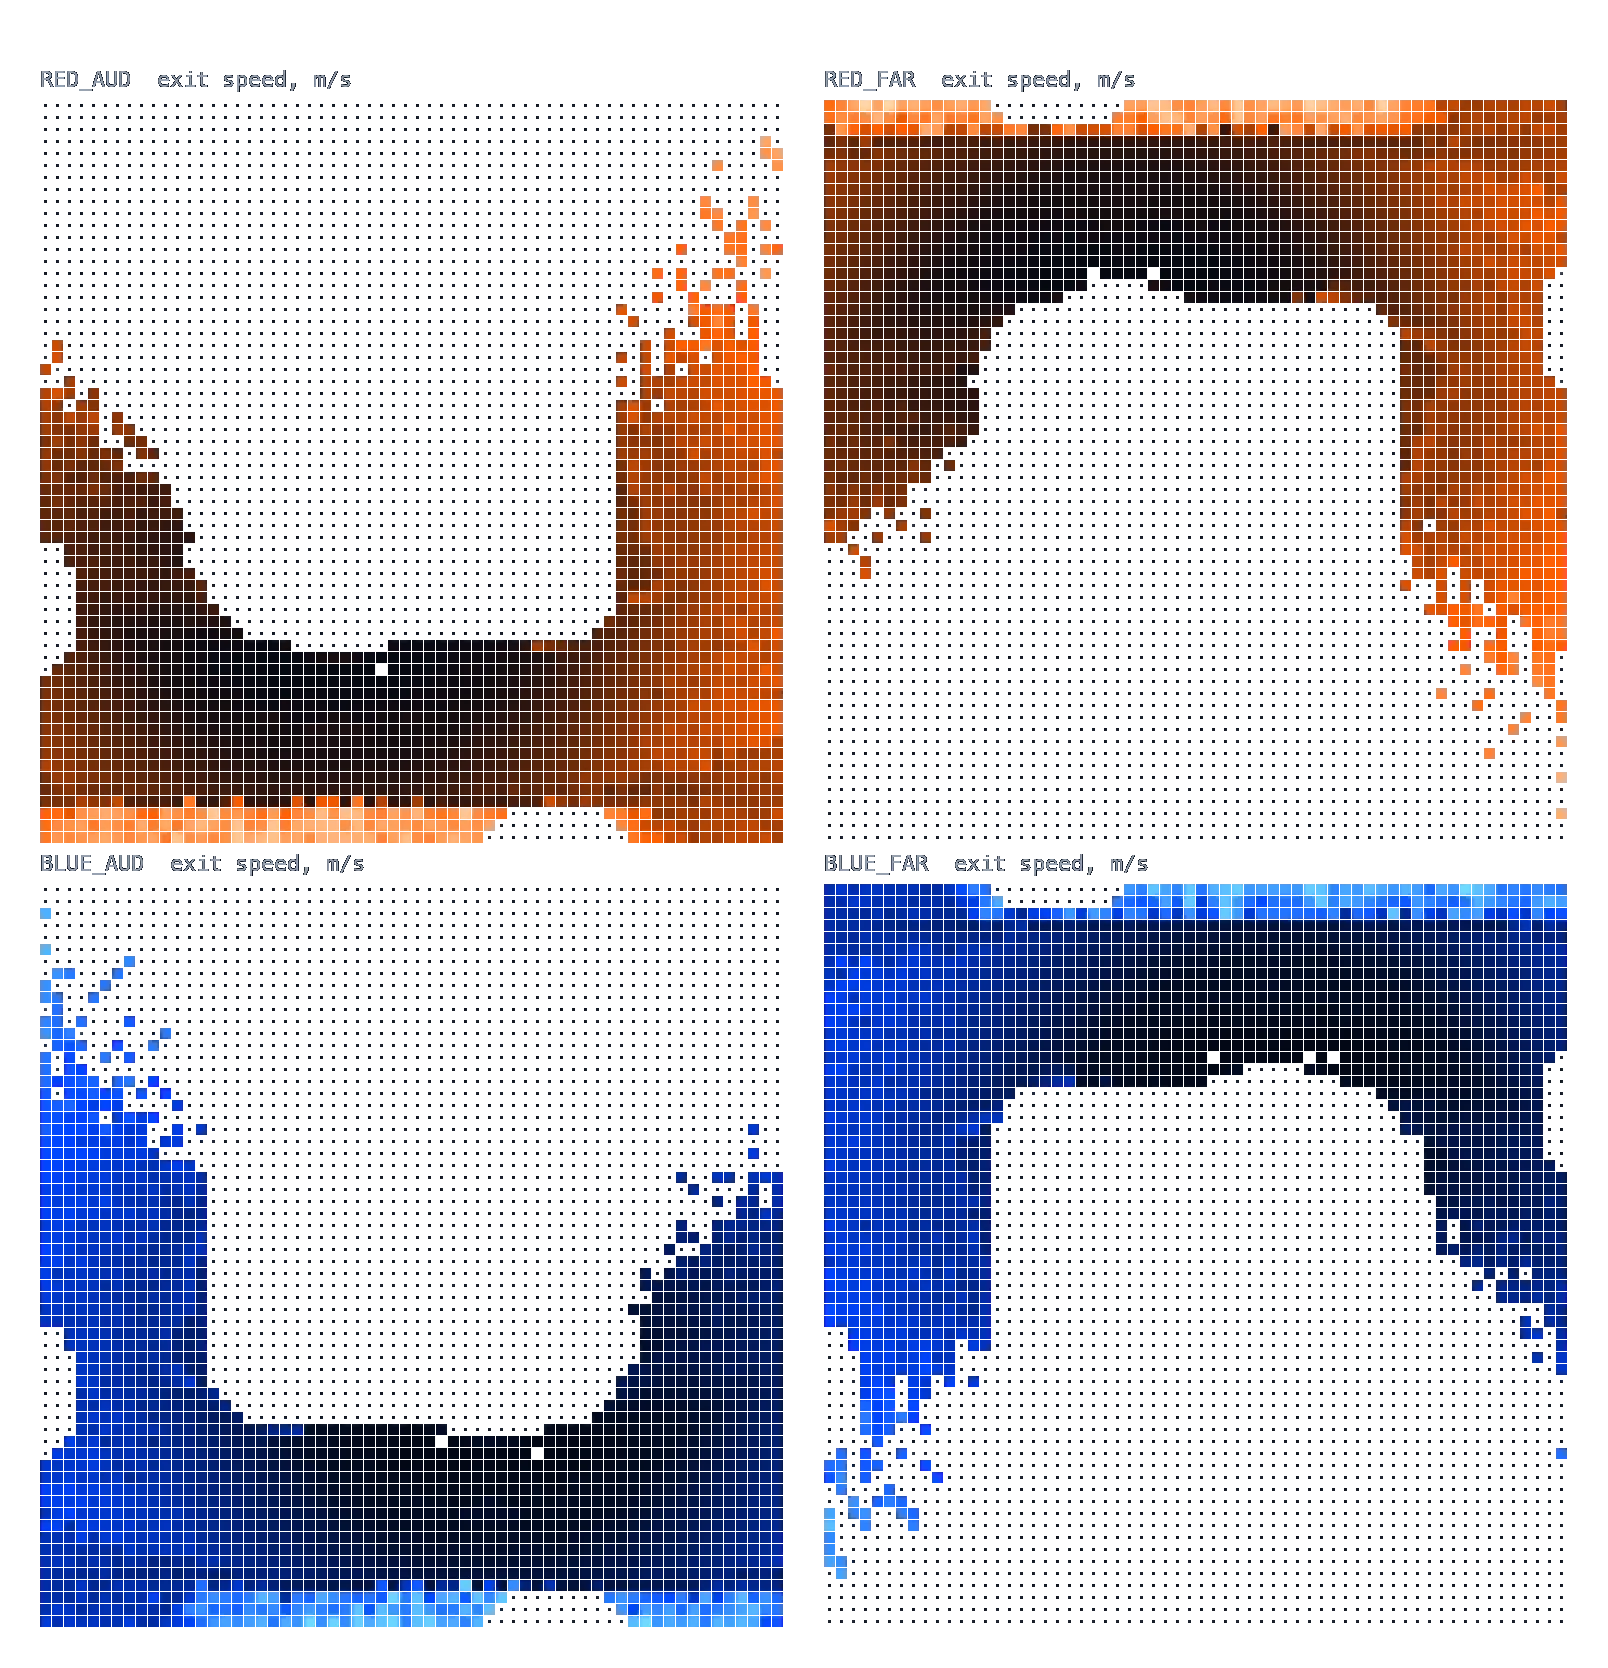
tools/export_hive_aim_table.py turns it into a table: for every 2 in spot on the field and each target, the launch angle, exit speed, flight time, and how much speed error the shot tolerates.HiveAimTableData.java. On the robot, HiveAimTable decodes it at init (about 10 ms) and blends the four nearest spots each loop, but only when their angles are close, so it never invents a shot between a lob and a direct one.The backdrop is that table: each square is a spot on the field, coloured by exit speed, one map per target.
Every commit in the BIOBUZZ repo now starts with the meet day, and badly named commits get fixed on their way in.