- Role
- Sole developer. Wrote the library and rebuilt our BIOBUZZ robot code on it to test it.
- Built with
- Java
- Ivy
- Pedro Pathing
- Started
- Oct 2026
- Finished
- Still going
Story
While planning ElectroDromos’s roadmap, a lot of ideas turned out not to be about path following at all. Running the intake partway through a path, timeouts, aiming the turret, choosing alliance in init: those are about commands and the OpMode. So they got their own library, built on Ivy.
To test it, I rebuilt our BIOBUZZ robot’s code on ElectroTelos and Ivy in a separate repo, so the competition code stays untouched.
How it works
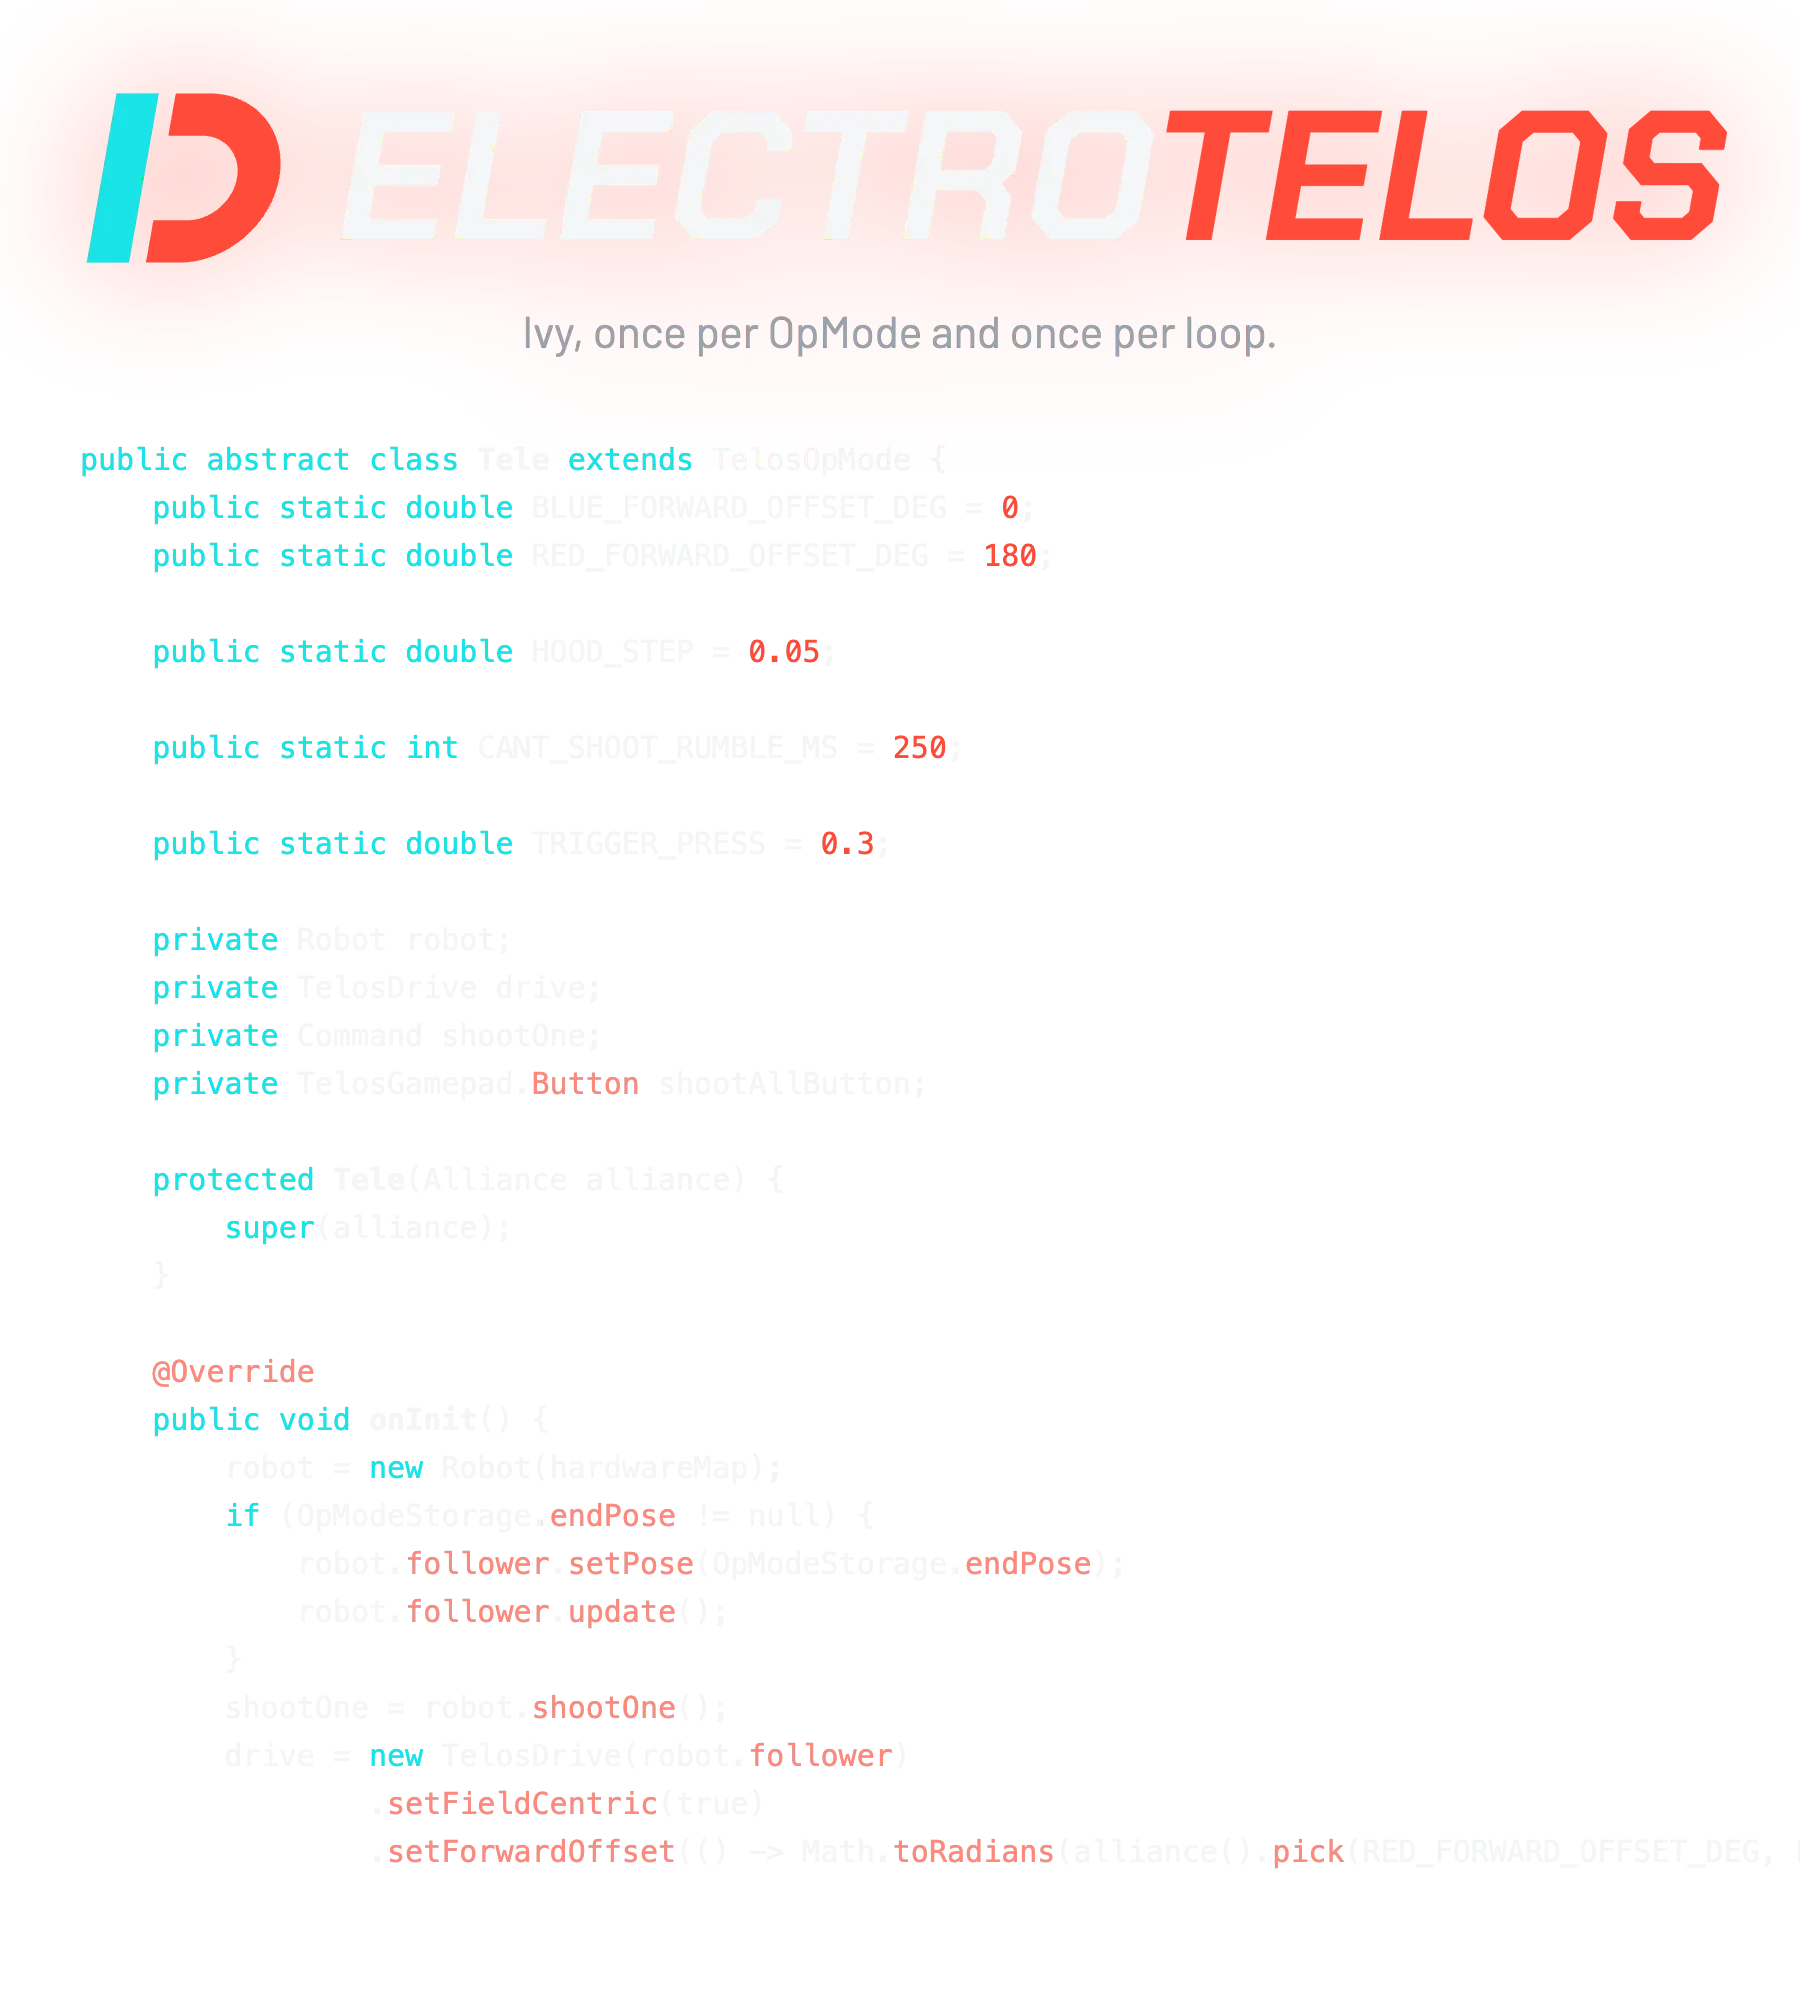
It’s at 0.0.1-PreAlpha. Teams keep stock Ivy, and their OpModes extend TelosOpMode, which owns the loop:
TelosOpMode: the base for auto and teleop. It knows the alliance (alliance().pick(red, blue)), and does bulk caching, so each loop reads every hub once instead of once per sensor.TelosGamepad: buttons and trigger thresholds withonPressandonRelease, so controls read as one line each.TelosDrive: field-centric driving on top of Pedro’s follower.TelosMotor,TelosServo,TelosPID: hardware and control helpers.
Our BIOBUZZ teleop on it is one class, with a red and a blue version that only pick the alliance. Planned next: path callbacks, step timeouts, waiting for mechanisms, telemetry throttling and motion profiles.